
Robotics · Simulation · Shared research
We're developing shared tests for robot capabilities across bodies, tasks and environments, in simulation and the physical world.
01 / INTERACTION
A moving world.
A familiar room becomes a different test when the dog moves. Timing, distance and the robot's view all matter.
Next: handling cloth02 / MANIPULATION
More than a grasp.
A towel changes shape as it moves. Object, grasp and starting position belong in the test, alongside the outcome.
Next: making coffee03 / COORDINATION
Work, in sequence.
Two arms share one work area. Action order, camera views and interruptions can change the outcome of the same task.
Next: loading the washer04 / COMPLETION
When is it done?
Clothes in, door clear, cycle ready. A useful comparison starts with a clear definition of finished.
From home to productionAcross embodiments
Across bodies.
A camera module passes between robots with different roles. Each handoff changes what needs to be seen, reached and coordinated.
The research
Keep the conditions.
Robot, policy, cameras, objects and starting state: our pilot will keep these with each outcome so a comparison can be repeated. Why EmbodiAtlas ↗
The first pilot
Choose the first tests.
Researchers, simulation builders and robotics teams can help choose the first tasks and setups. What would you want to compare? Talk with us ↗
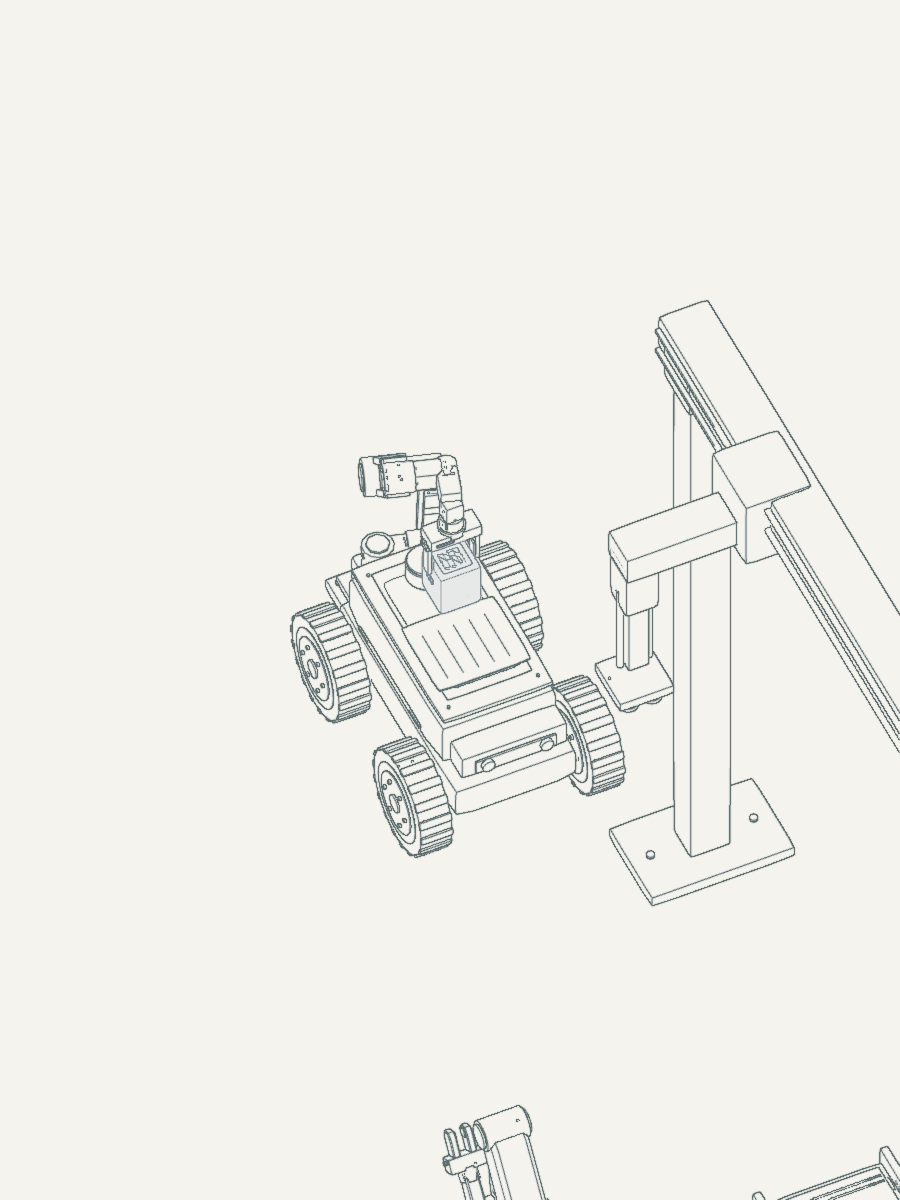
Receive the stereo vision module from RIG.
Get involved
Help shape the atlas.
Bring a research question, a simulation environment or a robot setup. Supporting partners can help make the first pilot possible.
Tell us about your work
A note to the team
Tell us about your setup, a question you want to test, or how you’d like to support the pilot.